
이미 소장하고 있다면 판매해 보세요.
- 국내배송만 가능
- 문화비소득공제 가능
책소개
목차
|
1 Introduction 1
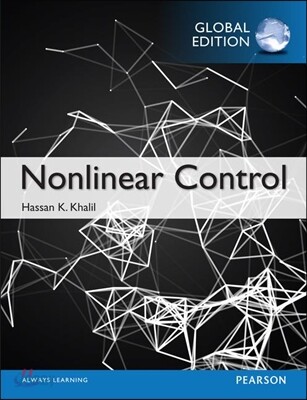
1.1 Nonlinear Models . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 1 1.2 Nonlinear Phenomena . . . . . . . . . . . . . . . . . . . . . . . . . . . 8 1.3 Overview of the Book . . . . . . . . . . . . . . . . . . . . . . . . . . . 9 1.4 Exercises . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 10 2 Two-Dimensional Systems 15 2.1 Qualitative Behavior of Linear Systems . . . . . . . . . . . . . . . . . . 17 2.2 Qualitative Behavior Near Equilibrium Points . . . . . . . . . . . . . . 21 2.3 Multiple Equilibria . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 24 2.4 Limit Cycles . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 27 2.5 Numerical Construction of Phase Portraits . . . . . . . . . . . . . . . . 31 2.6 Exercises . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 33 3 Stability of Equilibrium Points 37 3.1 Basic Concepts . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 37 3.2 Linearization . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 43 3.3 Lyapunov’s Method . . . . . . . . . . . . . . . . . . . . . . . . . . . . 45 3.4 The Invariance Principle . . . . . . . . . . . . . . . . . . . . . . . . . . 54 3.5 Exponential Stability . . . . . . . . . . . . . . . . . . . . . . . . . . . 58 3.6 Region of Attraction . . . . . . . . . . . . . . . . . . . . . . . . . . . . 61 3.7 Converse Lyapunov Theorems . . . . . . . . . . . . . . . . . . . . . . . 68 3.8 Exercises . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 70 4 Time-Varying and Perturbed Systems 75 4.1 Time-varying Systems . . . . . . . . . . . . . . . . . . . . . . . . . . . 75 4.2 Perturbed Systems . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 80 4.3 Boundedness and Ultimate Boundedness . . . . . . . . . . . . . . . . . 85 4.4 Input-to-State Stability . . . . . . . . . . . . . . . . . . . . . . . . . . 94 4.5 Exercises . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 99 5 Passivity 103 5.1 Memoryless Functions . . . . . . . . . . . . . . . . . . . . . . . . . . . 103 5.2 State Models . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 107 5.3 Positive Real Transfer Functions . . . . . . . . . . . . . . . . . . . . . 112 5.4 Connection with Lyapunov Stability . . . . . . . . . . . . . . . . . . . 115 5.5 Exercises . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 118 6 Input-Output Stability 121 6.1 L Stability . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 121 6.2 L Stability of State Models . . . . . . . . . . . . . . . . . . . . . . . . 127 6.3 L2 Gain . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 132 6.4 Exercises . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 137 7 Stability of Feedback Systems 141 7.1 Passivity Theorems . . . . . . . . . . . . . . . . . . . . . . . . . . . . 142 7.2 The Small-Gain Theorem . . . . . . . . . . . . . . . . . . . . . . . . . 152 7.3 Absolute Stability . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 155 7.3.1 Circle Criterion . . . . . . . . . . . . . . . . . . . . . . . . . . 157 7.3.2 Popov Criterion . . . . . . . . . . . . . . . . . . . . . . . . . . 164 7.4 Exercises . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 168 8 Special Nonlinear Forms 171 8.1 Normal Form . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 171 8.2 Controller Form . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 179 8.3 Observer Form . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 187 8.4 Exercises . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 194 9 State Feedback Stabilization 197 9.1 Basic Concepts . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 197 9.2 Linearization . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 199 9.3 Feedback Linearization . . . . . . . . . . . . . . . . . . . . . . . . . . 201 9.4 Partial Feedback Linearization . . . . . . . . . . . . . . . . . . . . . . 207 9.5 Backstepping . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 211 9.6 Passivity-Based Control . . . . . . . . . . . . . . . . . . . . . . . . . . 217 9.7 Control Lyapunov Functions . . . . . . . . . . . . . . . . . . . . . . . . 222 9.8 Exercises . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 227 10 Robust State Feedback Stabilization 231 10.1 Sliding Mode Control . . . . . . . . . . . . . . . . . . . . . . . . . . . 232 10.2 Lyapunov Redesign . . . . . . . . . . . . . . . . . . . . . . . . . . . . 251 10.3 High-Gain Feedback . . . . . . . . . . . . . . . . . . . . . . . . . . . 257 10.4 Exercises . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 259 11 Nonlinear Observers 263 11.1 Local Observers . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 264 11.2 The Extended Kalman Filter . . . . . . . . . . . . . . . . . . . . . . . 266 11.3 Global Observers . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 270 11.4 High-Gain Observers . . . . . . . . . . . . . . . . . . . . . . . . . . . . 271 11.5 Exercises . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 277 12 Output Feedback Stabilization 281 12.1 Linearization . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 282 12.2 Passivity-Based Control . . . . . . . . . . . . . . . . . . . . . . . . . . 283 12.3 Observer-Based Control . . . . . . . . . . . . . . . . . . . . . . . . . . 286 12.4 High-Gain Observers and the Separation Principle . . . . . . . . . . . . 288 12.5 Robust Stabilization of Minimum Phase Systems . . . . . . . . . . . . 296 12.5.1 Relative Degree One . . . . . . . . . . . . . . . . . . . . . . . 296 12.5.2 Relative Degree Higher Than One . . . . . . . . . . . . . . . 298 12.6 Exercises . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 304 13 Tracking and Regulation 307 13.1 Tracking . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 310 13.2 Robust Tracking . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 312 13.3 Transition Between Set Points . . . . . . . . . . . . . . . . . . . . . . 314 13.4 Robust Regulation via Integral Action . . . . . . . . . . . . . . . . . . 318 13.5 Output Feedback . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 322 13.6 Exercises . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 325 A Examples 329 A.1 Pendulum . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 329 A.2 Mass?Spring System . . . . . . . . . . . . . . . . . . . . . . . . . . . . 331 A.3 Tunnel-Diode Circuit . . . . . . . . . . . . . . . . . . . . . . . . . . . 333 A.4 Negative-Resistance Oscillator . . . . . . . . . . . . . . . . . . . . . . 335 A.5 DC-to-DC Power Converter . . . . . . . . . . . . . . . . . . . . . . . . 337 A.6 Biochemical Reactor . . . . . . . . . . . . . . . . . . . . . . . . . . . . 338 A.7 DC Motor . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 339 A.8 Magnetic Levitation . . . . . . . . . . . . . . . . . . . . . . . . . . . . 340 A.9 Electrostatic Microactuator . . . . . . . . . . . . . . . . . . . . . . . . 342 A.10 Robot Manipulator . . . . . . . . . . . . . . . . . . . . . . . . . . . . 344 A.11 Inverted Pendulum on a Cart . . . . . . . . . . . . . . . . . . . . . . . 344 A.12 Translational Oscillator with Rotating Actuator . . . . . . . . . . . . . 347 B Mathematical Review 349 C Composite Lyapunov Functions 355 C.1 Cascade Systems . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 355 C.2 Interconnected systems . . . . . . . . . . . . . . . . . . . . . . . . . . 357 C.3 Singularly Perturbed Systems . . . . . . . . . . . . . . . . . . . . . . . 359 D Proofs 363 |
품목정보
- 발행일
- 2014년 08월 20일
- 쪽수, 무게, 크기
- 400쪽 | 492g | 188*232*13mm
- ISBN13
- 9781292060507
리뷰/한줄평0
상품정보안내
직수입외서의 경우, 해외거래처에서 제공하는 정보가 부족하여 제목, 표지, 가격, 유통상태 등의 정보가 미비하거나 변경되는 경우가 있습니다. 정확한 확인을 원하시는 경우, 일대일 상담으로 문의하여 주시면 답변 드리겠습니다.
(판형과 판수 등이 다양한 도서는 찾으시는 도서의 ISBN을 알려 주시면 보다 빠르고 정확한 안내가 가능합니다.)
해외거래처에서 품절인 경우, 2차 거래선을 통해 유럽과 미국 출판사로 직접 수입이 진행될 수 있습니다.
수입 진행 시점으로 부터 2~3주가 추가로 소요되며, 해외에서도 유통이 원활하지 않은 도서는 품절 안내가 지연될 수 있습니다.
해당 경우, 문자와 메일로 별도 안내를 드리고 있사오니 마이페이지에서 휴대전화번호와 메일주소를 다시 한번 확인해주시기 바랍니다.
(판형과 판수 등이 다양한 도서는 찾으시는 도서의 ISBN을 알려 주시면 보다 빠르고 정확한 안내가 가능합니다.)
해외거래처에서 품절인 경우, 2차 거래선을 통해 유럽과 미국 출판사로 직접 수입이 진행될 수 있습니다.
수입 진행 시점으로 부터 2~3주가 추가로 소요되며, 해외에서도 유통이 원활하지 않은 도서는 품절 안내가 지연될 수 있습니다.
해당 경우, 문자와 메일로 별도 안내를 드리고 있사오니 마이페이지에서 휴대전화번호와 메일주소를 다시 한번 확인해주시기 바랍니다.
48,000원
총 1개
48,000원
