
소득공제
수입
직수입양서
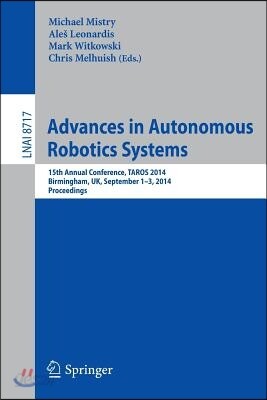
Advances in Autonomous Robotics Systems
15th Annual Conference, TAROS 2014, Birmingham, UK, September 1-3, 2014. Proceedings
Paperback, POD 주문제작도서
Melhuish, Chris(EDT)
Springer International Publishing AG
2014.08.05.
- 주문 제작 (POD) 도서로 제본 및 인쇄 품질이 다소 미흡할 수 있습니다 (해당 사유 반품 불가)
이미 소장하고 있다면 판매해 보세요.
- 국내배송만 가능
- 해외 거래처 사정에 의하여 품절/지연 가능
- 도서 정보 중 미표기 사항 안내?
- 문화비소득공제 가능
Lecture Notes in Computer Science / Lecture Notes in Artific
-
 Controlled Natural Language: 4th International Workshop, Cnl 2014, Galway, Ireland, August 20-22, 2014, Proceedings 이동Controlled Natural Language: 4th International Workshop, Cnl 2014, Galway, Ireland, August 20-22, 2014, Proceedings93,480원
-
Brain Informatics and Health: International Conference, Bih 2014, Warsaw, Poland, August 11-14, 2014.Proceedings 이동Brain Informatics and Health: International Conference, Bih 2014, Warsaw, Poland, August 11-14, 2014.Proceedings93,480원
-
Computational Processing of the Portuguese Language: 11th International Conference, Propor 2014, Sao Carlos/Sp, Brazil, October 6-8, 2014, Proceedings 이동Computational Processing of the Portuguese Language: 11th International Conference, Propor 2014, Sao Carlos/Sp, Brazil, October 6-8, 2014, Proceedings93,480원
책소개
목차
|
- Modeling of a Large Structured Environment: With a Repetitive Canonical Geometric-Semantic Model.
- Monte Carlo Localization for Teach-and-Repeat Feature-Based Navigation. - An Improved Cellular Automata-Based Model for Robot Path-Planning. - Bioinspired Mechanisms and Sensorimotor Schemes for Flying: A Preliminary Study for a Robotic Bat. - Evolutionary Coordination System for Fixed-Wing Communications Unmanned Aerial Vehicles. - Multi-agent Environment Exploration with AR.Drones. - H Path Tracking Control for Quadrotors Based on Quaternion Representation. - Towards an Ethical Robot: Internal Models, Consequences and Ethical Action Selection. - The Fridge Door is Open Temporal Verification of a Robotic Assistant s Behaviours. - Implementation and Test of Human-Operated and Human-Like Adaptive Impedance Controls on Baxter Robot. - Hybrid Communication System for Long Range Resource Tracking in Search and Rescue Scenarios. - Wearable Self Sufficient MFC Communication System Powered by Urine. - Morphogenetic Self-Organization of Collective Movement without Directional Sensing. - The Pi Swarm: A Low-Cost Platform for Swarm Robotics Research and Education. - Tactile Features: Recognising Touch Sensations with a Novel and Inexpensive Tactile Sensor. - Polygonal Models for Clothing. - Design of a Multi-purpose Low-Cost Mobile Robot for Research and Education. - Adaptive Swarm Robot Region Coverage Using Gene Regulatory Networks. - Communicating Unknown Objects to Robots through Pointing Gestures. - A Cost-Effective Automatic 3D Reconstruction Pipeline for Plants Using Multi-view Images. - Improving the Generation of Rapidly Exploring Randomised Trees (RRTs) in Large Scale Virtual Environments Using Trails. - Intelligent Computation of Inverse Kinematics of a 5-dof Manipulator Using MLPNN. - Humanoid Robot Gait Generator: Foot Steps Calculation for Trajectory Following. - A Method for Matching Desired Non-Feature Points to Size Martian Rocks Based upon SIFT. - CogLaboration: Towards Fluent Human-Robot Object Handover Interactions. - euRathlon Outdoor Robotics Challenge: Year 1 Report. - FROctomap: An Efficient Spatio-Temporal Environment Representation. - Combined Force and Position Controller Based on Inverse Dynamics: Application to Cooperative Robotics (Extended Abstract). - Learning Objects from RGB-D Sensors for Cleaning Tasks Using a Team of Cooperative Humanoid Robots. - Acoustic Based Search and Rescue on a UAV. - Visual Commands for Tracking and Control. - A Novel Saliency Method Based on Restricted Boltzmann Machine (RBM) and Its Application to Planetary Exploration. |
관련 분류
품목정보
- 발행일
- 2014년 08월 05일
- 쪽수, 무게, 크기
- 쪽수확인중 | 458g | 155*235*16mm
- ISBN13
- 9783319104003
리뷰/한줄평0
상품정보안내
직수입외서의 경우, 해외거래처에서 제공하는 정보가 부족하여 제목, 표지, 가격, 유통상태 등의 정보가 미비하거나 변경되는 경우가 있습니다. 정확한 확인을 원하시는 경우, 일대일 상담으로 문의하여 주시면 답변 드리겠습니다.
(판형과 판수 등이 다양한 도서는 찾으시는 도서의 ISBN을 알려 주시면 보다 빠르고 정확한 안내가 가능합니다.)
해외거래처에서 품절인 경우, 2차 거래선을 통해 유럽과 미국 출판사로 직접 수입이 진행될 수 있습니다.
수입 진행 시점으로 부터 2~3주가 추가로 소요되며, 해외에서도 유통이 원활하지 않은 도서는 품절 안내가 지연될 수 있습니다.
해당 경우, 문자와 메일로 별도 안내를 드리고 있사오니 마이페이지에서 휴대전화번호와 메일주소를 다시 한번 확인해주시기 바랍니다.
(판형과 판수 등이 다양한 도서는 찾으시는 도서의 ISBN을 알려 주시면 보다 빠르고 정확한 안내가 가능합니다.)
해외거래처에서 품절인 경우, 2차 거래선을 통해 유럽과 미국 출판사로 직접 수입이 진행될 수 있습니다.
수입 진행 시점으로 부터 2~3주가 추가로 소요되며, 해외에서도 유통이 원활하지 않은 도서는 품절 안내가 지연될 수 있습니다.
해당 경우, 문자와 메일로 별도 안내를 드리고 있사오니 마이페이지에서 휴대전화번호와 메일주소를 다시 한번 확인해주시기 바랍니다.
93,480원
총 1개
93,480원
