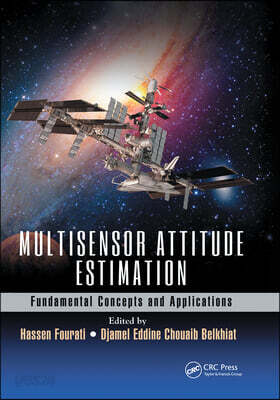
- 주문 제작 (POD) 도서로 제본 및 인쇄 품질이 다소 미흡할 수 있습니다 (해당 사유 반품 불가)
이미 소장하고 있다면 판매해 보세요.
- 국내배송만 가능
- 해외 거래처 사정에 의하여 품절/지연 가능
- 도서 정보 중 미표기 사항 안내?
- 문화비소득공제 가능
Devices, Circuits, and Systems
-
 Flexible, Wearable, and Stretchable Electronics 이동Flexible, Wearable, and Stretchable Electronics10% 124,090원
-
Spectral, Photon Counting Computed Tomography 이동Spectral, Photon Counting Computed Tomography10% 153,540원
-
Physical Design for 3D Integrated Circuits 이동Physical Design for 3D Integrated Circuits10% 153,540원
-
Low Power Semiconductor Devices and Processes for Emerging Applications in Communications, Computing, and Sensing 이동Low Power Semiconductor Devices and Processes for Emerging Applications in Communications, Computing, and Sensing10% 132,500원
-
Structural Health Monitoring of Composite Structures Using Fiber Optic Methods 이동Structural Health Monitoring of Composite Structures Using Fiber Optic Methods10% 191,410원
-
Low Power Circuits for Emerging Applications in Communications, Computing, and Sensing 이동Low Power Circuits for Emerging Applications in Communications, Computing, and Sensing10% 132,500원
-
Flexible, Wearable, and Stretchable Electronics 이동Flexible, Wearable, and Stretchable Electronics10% 307,120원
책소개
목차
|
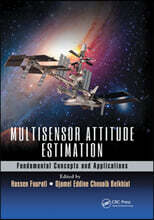
Section I Preliminaries on Attitude Representations and Rotations. What Are Quaternions and Why Haven’t I Heard of Them? Rotation in 3D Space. Attitude Parametrization, Kinematics, and Dynamics. Section II Multisensor Filtering for Attitude Estimation: Theories and Applications. Stable Estimation of Rigid Body Motion Based on the Lagrange?d’Alembert Principle. The Additive and Multiplicative Approaches to Quaternion Kalman Filtering. Spacecraft Attitude Determination. How to Deal with the External Acceleration When Estimating the Attitude Using Inertial Measurement Units: A Linear Kalman-Based Filtering Approach. From Attitude Estimation to Pose Estimation Using Dual Quaternions. Distributed Estimation for Spatial Rigid Motion Based on Dual Quaternions. A Quaternion Orientation from Earth Field Observations Using the Algebraic Quaternion Algorithm: Analysis and Applications in Fusion Algorithms. Recent Nonlinear Attitude Estimation Algorithms. Low Complexity Sensor Fusion Solution for Accurate Estimation of Gravity and Linear Acceleration. Deterministic Attitude Estimation. Attitude Estimations with Intermittent Observations. Estimation of Attitude from a Single-Direction Sensor. Cooperative Attitude Estimation Based on Remote-Access Observations. Nonlinear Observer for Attitude, Position, and Velocity: Theory and Experiments. Spacecraft Attitude Estimation Using Sparse Grid Quadrature Filtering. Attitude Estimation for Small, Low-Cost UAVs: A Tutorial Approach. 3D Orientation Estimation Using Wearable MEMS Inertial/Magnetic Sensors. Adaptive Data Fusion of Multiple Sensors for Vehicle Pose Estimation. Optimal Invariant Observers Theory for Nonlinear State Estimation. Design and Implementation of Low-Cost Attitude Heading References Systems for Micro Aerial Vehicles. Small Satellite Attitude Determination. A Hybrid Data Fusion Approach for Robust Attitude Estimation. Integration of Single-Frame and Filtering Methods for Nanosatellite Attitude Estimation. Ego-Motion Tracking in Dynamic Environments Using Wearable Visual-Inertial Sensors. Attitude Estimation for a Small-Scale Flybarless Helicopter. A Comparison of Multisensor Attitude Estimation Algorithms. Low-Cost and Accurate Reconstruction of Postures via IMU. Attitude Estimation of a UAV Using Optical Flow. Index. |
관련 분류
품목정보
- 발행일
- 2020년 09월 30일
- 쪽수, 무게, 크기
- 580쪽 | 1120g | 180*250mm
- ISBN13
- 9780367655815
사락 별점0
혜택 및 유의사항밑줄0
혜택 및 유의사항상품정보안내
(판형과 판수 등이 다양한 도서는 찾으시는 도서의 ISBN을 알려 주시면 보다 빠르고 정확한 안내가 가능합니다.)
해외거래처에서 품절인 경우, 2차 거래선을 통해 유럽과 미국 출판사로 직접 수입이 진행될 수 있습니다.
수입 진행 시점으로 부터 2~3주가 추가로 소요되며, 해외에서도 유통이 원활하지 않은 도서는 품절 안내가 지연될 수 있습니다.
해당 경우, 문자와 메일로 별도 안내를 드리고 있사오니 마이페이지에서 휴대전화번호와 메일주소를 다시 한번 확인해주시기 바랍니다.